
Introduction — Why this matters to you right now
Ever wondered why a simple motor spec can wreck an entire project? That’s the situation I see all the time: a tight deadline, a tricky load profile, and a motor that just won’t behave. As an electric motor manufacturer, you’re juggling thermal limits, supply chain delays, and efficiency targets every week. Recent industry figures show that nearly 40% of project overruns trace back to mismatched motor selections or hidden torque issues — so what are we missing?
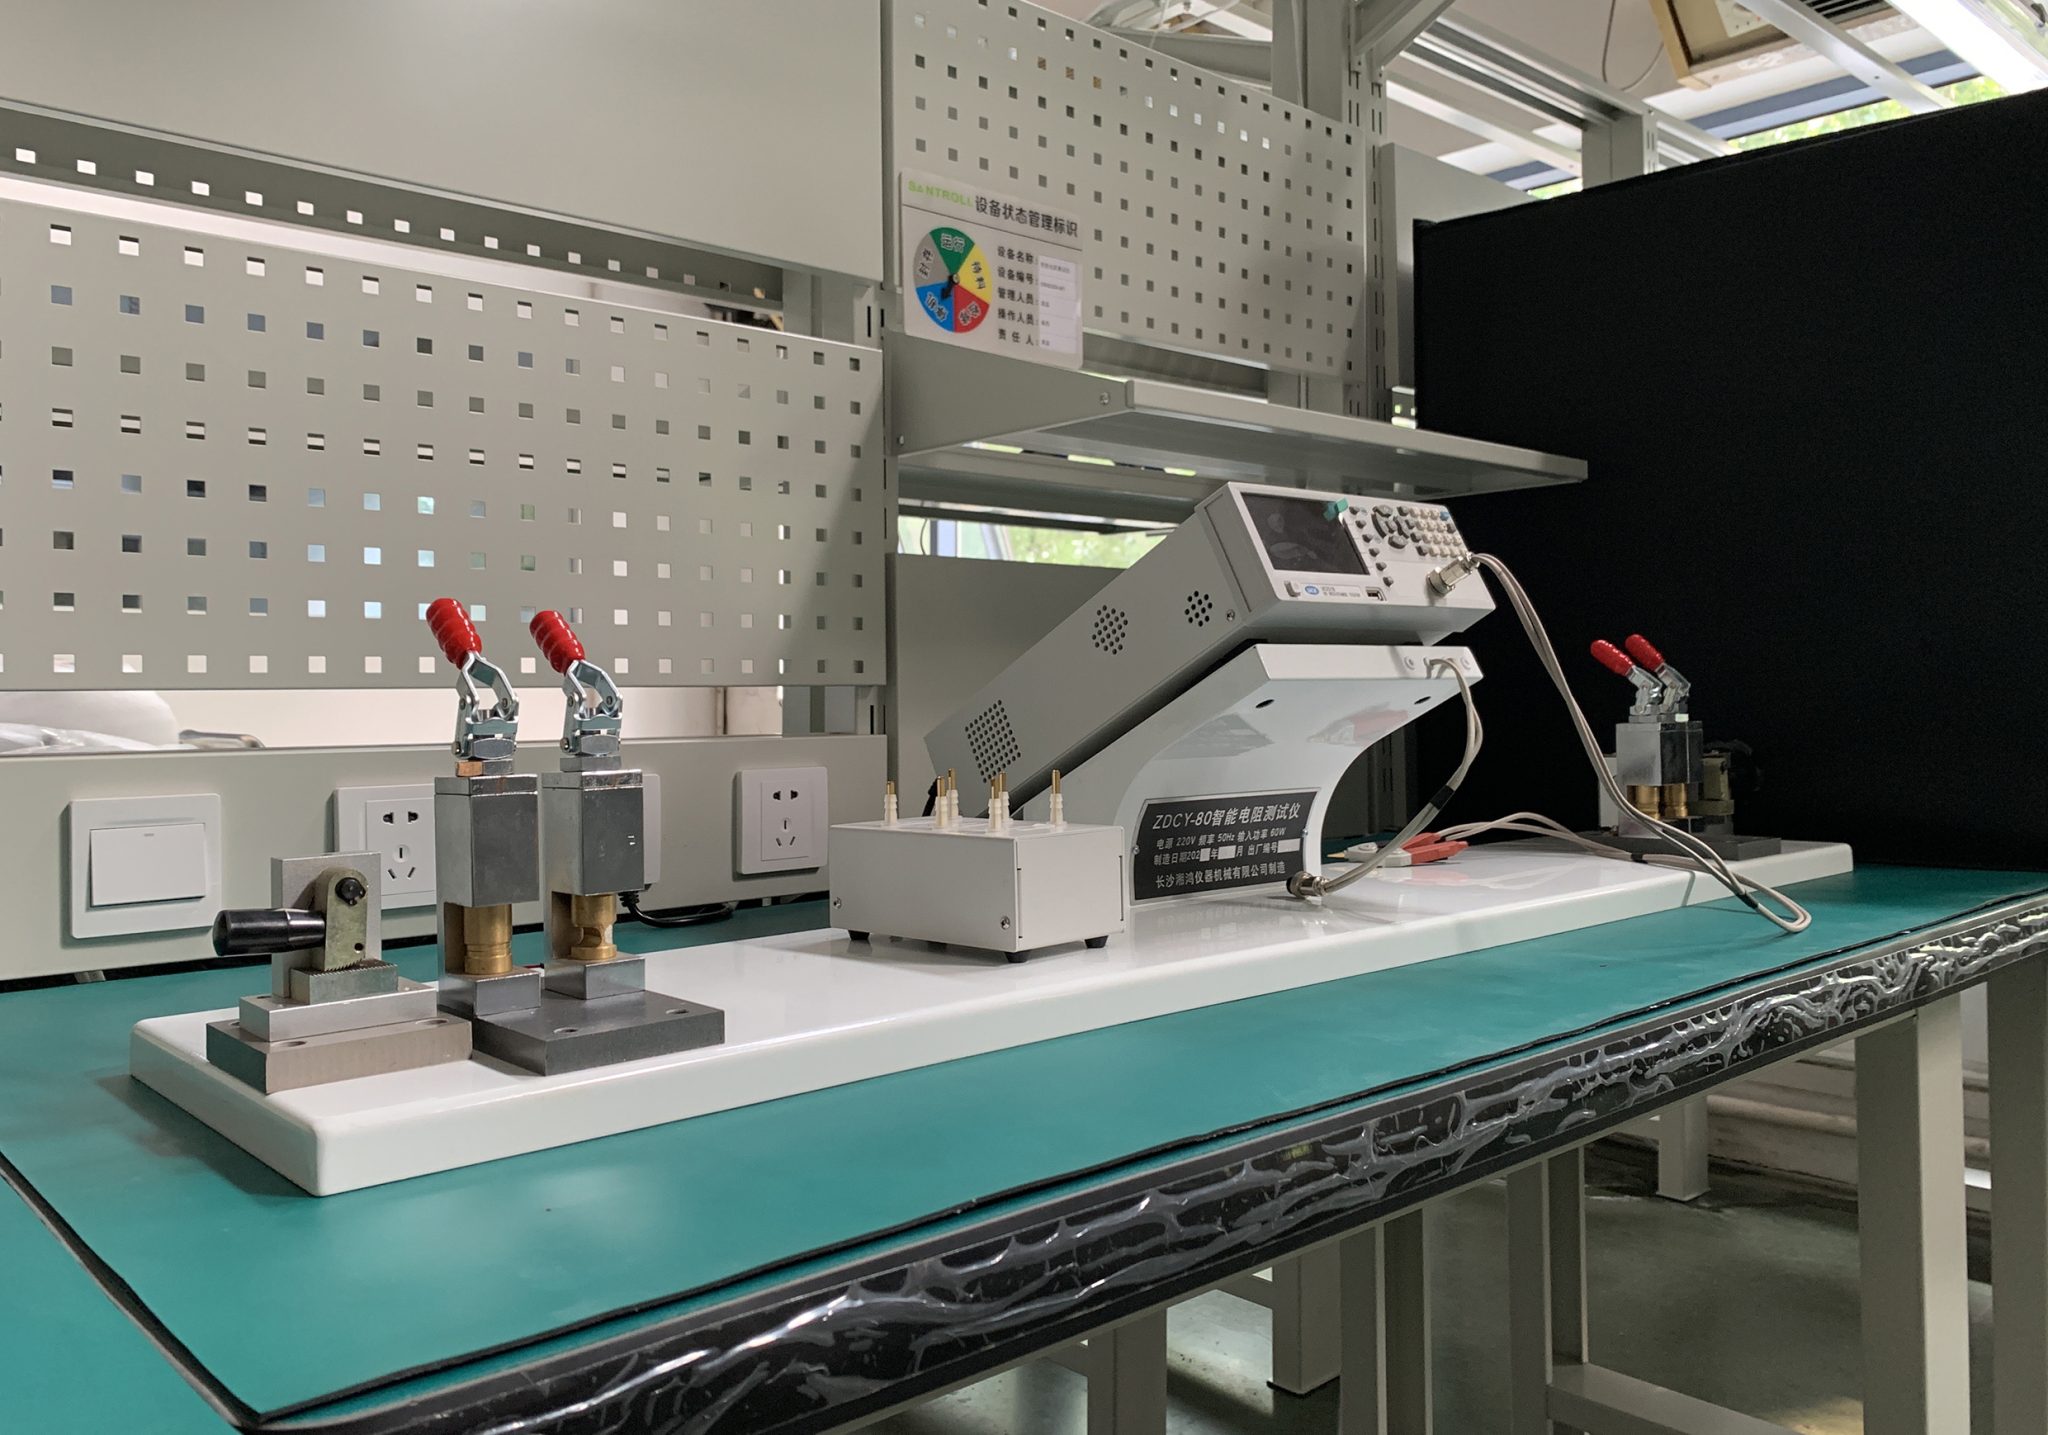
I’ll be blunt: most guides skim the obvious stuff and skip the nastier edge cases. I want to dig into those corners with you (no fluff) — think stator heat soak, cogging torque surprises, and how power converters interact with control loops. We’ll ask the hard questions and map practical fixes. Ready to roll? Here’s where we start — and then we go deeper.
Traditional Flaws and Hidden Pain Points in Boat Motor Manufacturers
boat motor manufacturers often face a unique mix of stresses: salt, shock, and sustained low-speed torque demands. I’ve watched teams pick motors that look perfect on paper but fail under real marine loads. The classic culprits? Oversized peak torque specs that hide steady-state heating, overlooked cogging torque that ruins low-speed thrust, and narrow control-bandwidth on the inverter — all of which bite you during sea trials. Look, it’s simpler than you think when you actually test under working conditions.
Why do these gaps persist?
Because design checks often stop at datasheets. We focus on peak horsepower and ignore the transient behavior caused by rotor-stator interactions. Add in variable power converters and older brushless DC controllers, and the system gets twitchy. I’ve seen projects where the rotor overheated after two hours at half load — no one expected that. The truth: lab tests rarely mimic spray, drag, or intermittent loading. So the hidden pain point isn’t just the motor — it’s the whole mechanical-electrical system failing to be tested together. — funny how that works, right?
Future Outlook: New Principles for Motor Manufacturing and Selection
Shift your view from isolated specs to system-level resilience. In motor manufacturing, that means designing for thermal headroom, better electromagnetic damping, and smarter integration with power electronics. I’m talking about sensors that report winding temperature in real time, inverters that adapt switching patterns to reduce torque ripple, and assembly practices that cut mechanical misalignment. These aren’t buzzwords; they’re practical controls that save expensive retrofit work later.
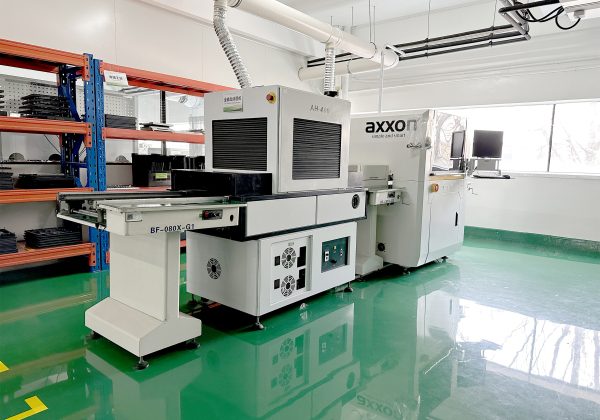
What’s next for makers and integrators?
Case studies show that adding closed-loop thermal monitoring plus modest changes to the stator winding pattern can extend safe continuous operation by a third. We should also plan for predictive maintenance: a few low-cost temperature and vibration sensors feed into simple edge computing nodes that flag anomalies before failure. It’s a small upfront cost and — trust me — it pays off in fewer emergency callouts and happier operators.
To evaluate new motor options, I recommend three metrics you can actually measure: 1) Continuous thermal margin under representative load cycles; 2) Measured torque ripple and cogging torque at low RPM; 3) System-level efficiency including inverter losses (not just motor efficiency). Use these, and you’ll avoid the common traps we’ve just covered. In my experience, teams that adopt this approach reduce field failures and downtime significantly — measurable gains, not just theory.
For more practical solutions and component choices, check the people behind these ideas — Santroll. I’ve worked alongside engineers who apply these principles every day, and I can tell you: it changes outcomes.